X-Humanoid, the Beijing Humanoid Robot Innovation Center, has released Hi-WBC, a general whole-body control model for humanoid robots, through its embodied-intelligence platform. The company announced the model on November 2 and detailed it in a Chinese press release on November 7. Hi-WBC stands for Whole-Body Control for Humanoid Intelligence.
The model treats motion references taken from human movement as a guide rather than a script to reproduce exactly. X-Humanoid says Hi-WBC combines those references with robot dynamics and environmental constraints, so a robot can keep the intent of a movement while adjusting posture, joint motion and support to the load, external forces and terrain it actually faces.
The company describes three capability areas. To keep adding skills without losing old ones, Hi-WBC uses a framework based on mixture-of-experts and policy distillation: specialist expert policies learn particular movements or manipulation tasks, and their abilities are then distilled into a general policy. For heavy loads and physical interaction, a contact-aware learning approach estimates external forces from joint currents and motion states and combines that with short-horizon dynamics optimization and reinforcement learning.
For uneven ground, a perceptive control approach uses terrain geometry to identify viable footholds and adjust foot placement, leg swing and body posture on slopes, steps and obstacles. The release says the robot can choose how and when to clear an obstacle and then resume walking.
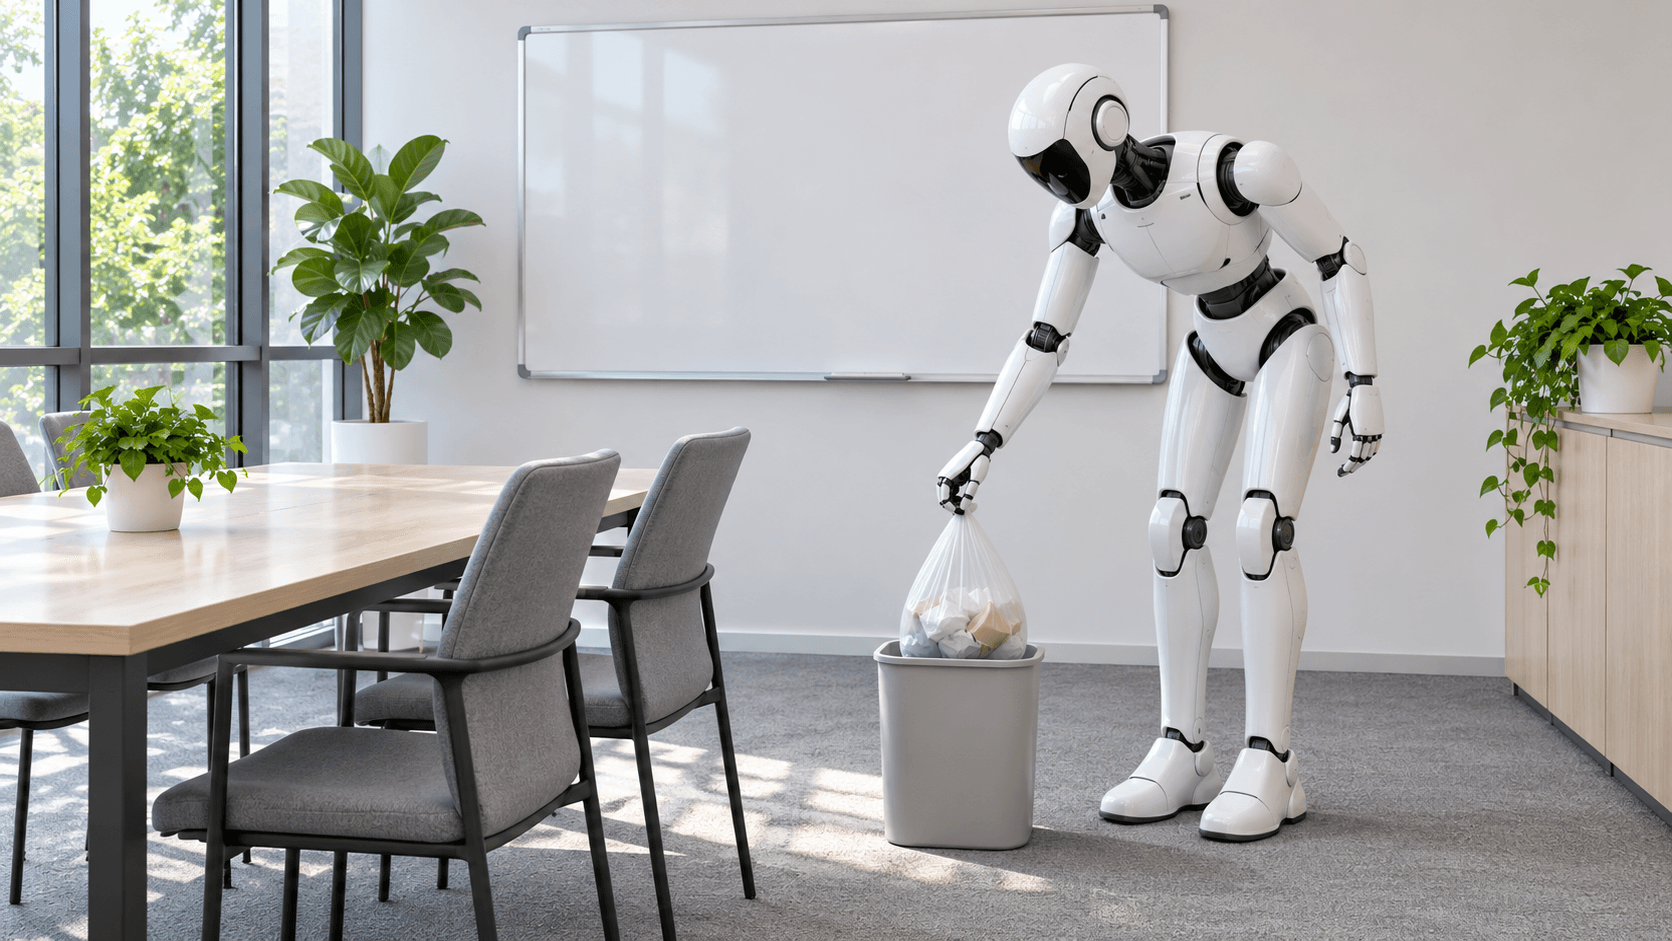
X-Humanoid released two demonstration videos. One links the model to its Tiangong robots' results in the all-round five-event competition at a robot sports event, where the company says Tiangong robots took gold and silver and was the only bipedal humanoid to win gold in the scenario events. The other shows several robots tidying a meeting room in a single continuous shot: picking up a remote control and desk clutter, moving and returning chairs, shifting a whiteboard, lifting a trash bag and squatting to pick up paper from the floor.
Those clips are company demonstrations rather than evidence of commercial deployment, and the release does not give task success rates, payload limits or availability for customers. X-Humanoid says Hi-WBC connects to its platform's task-decision and multi-robot scheduling system and will be improved with execution feedback from real robots.
SEE ALSO: X-Humanoid Sets Out Its Roadmap for a Unified Embodied Model and Self-Evolving Robot Policies
评论交流(0)
登录后即可参与评论交流,立即登录 / 注册
还没有评论,来抢沙发~